
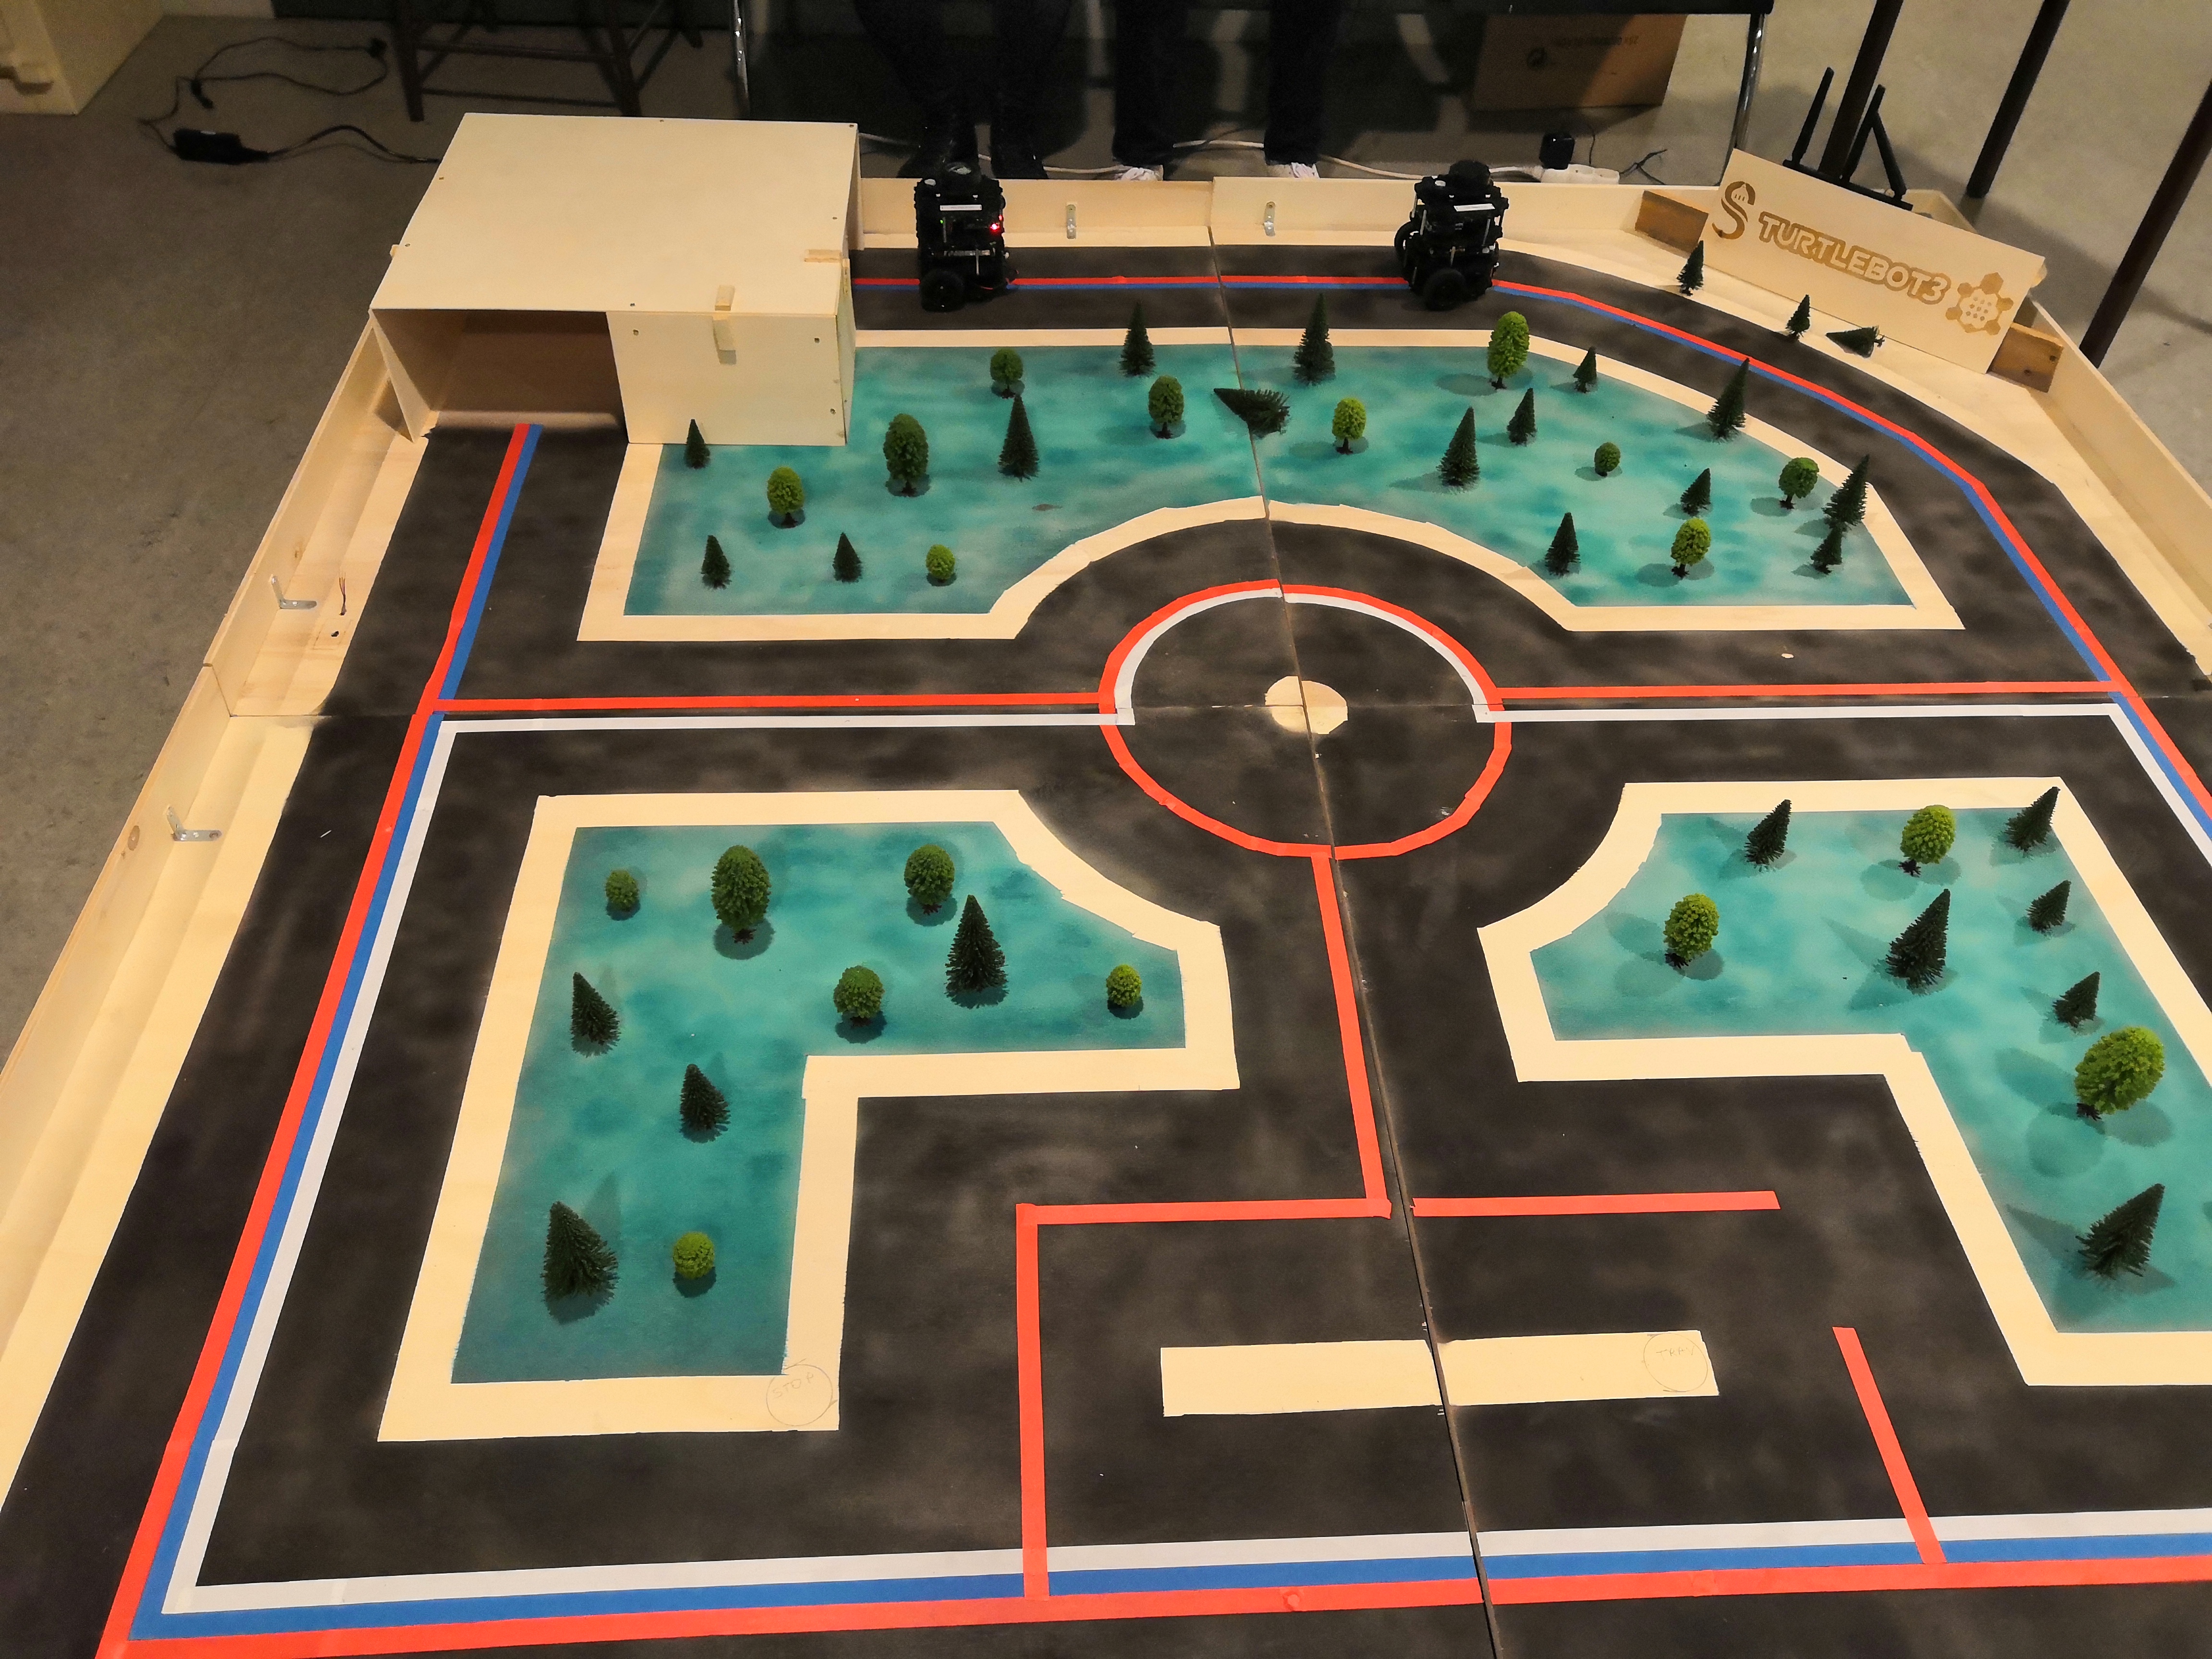
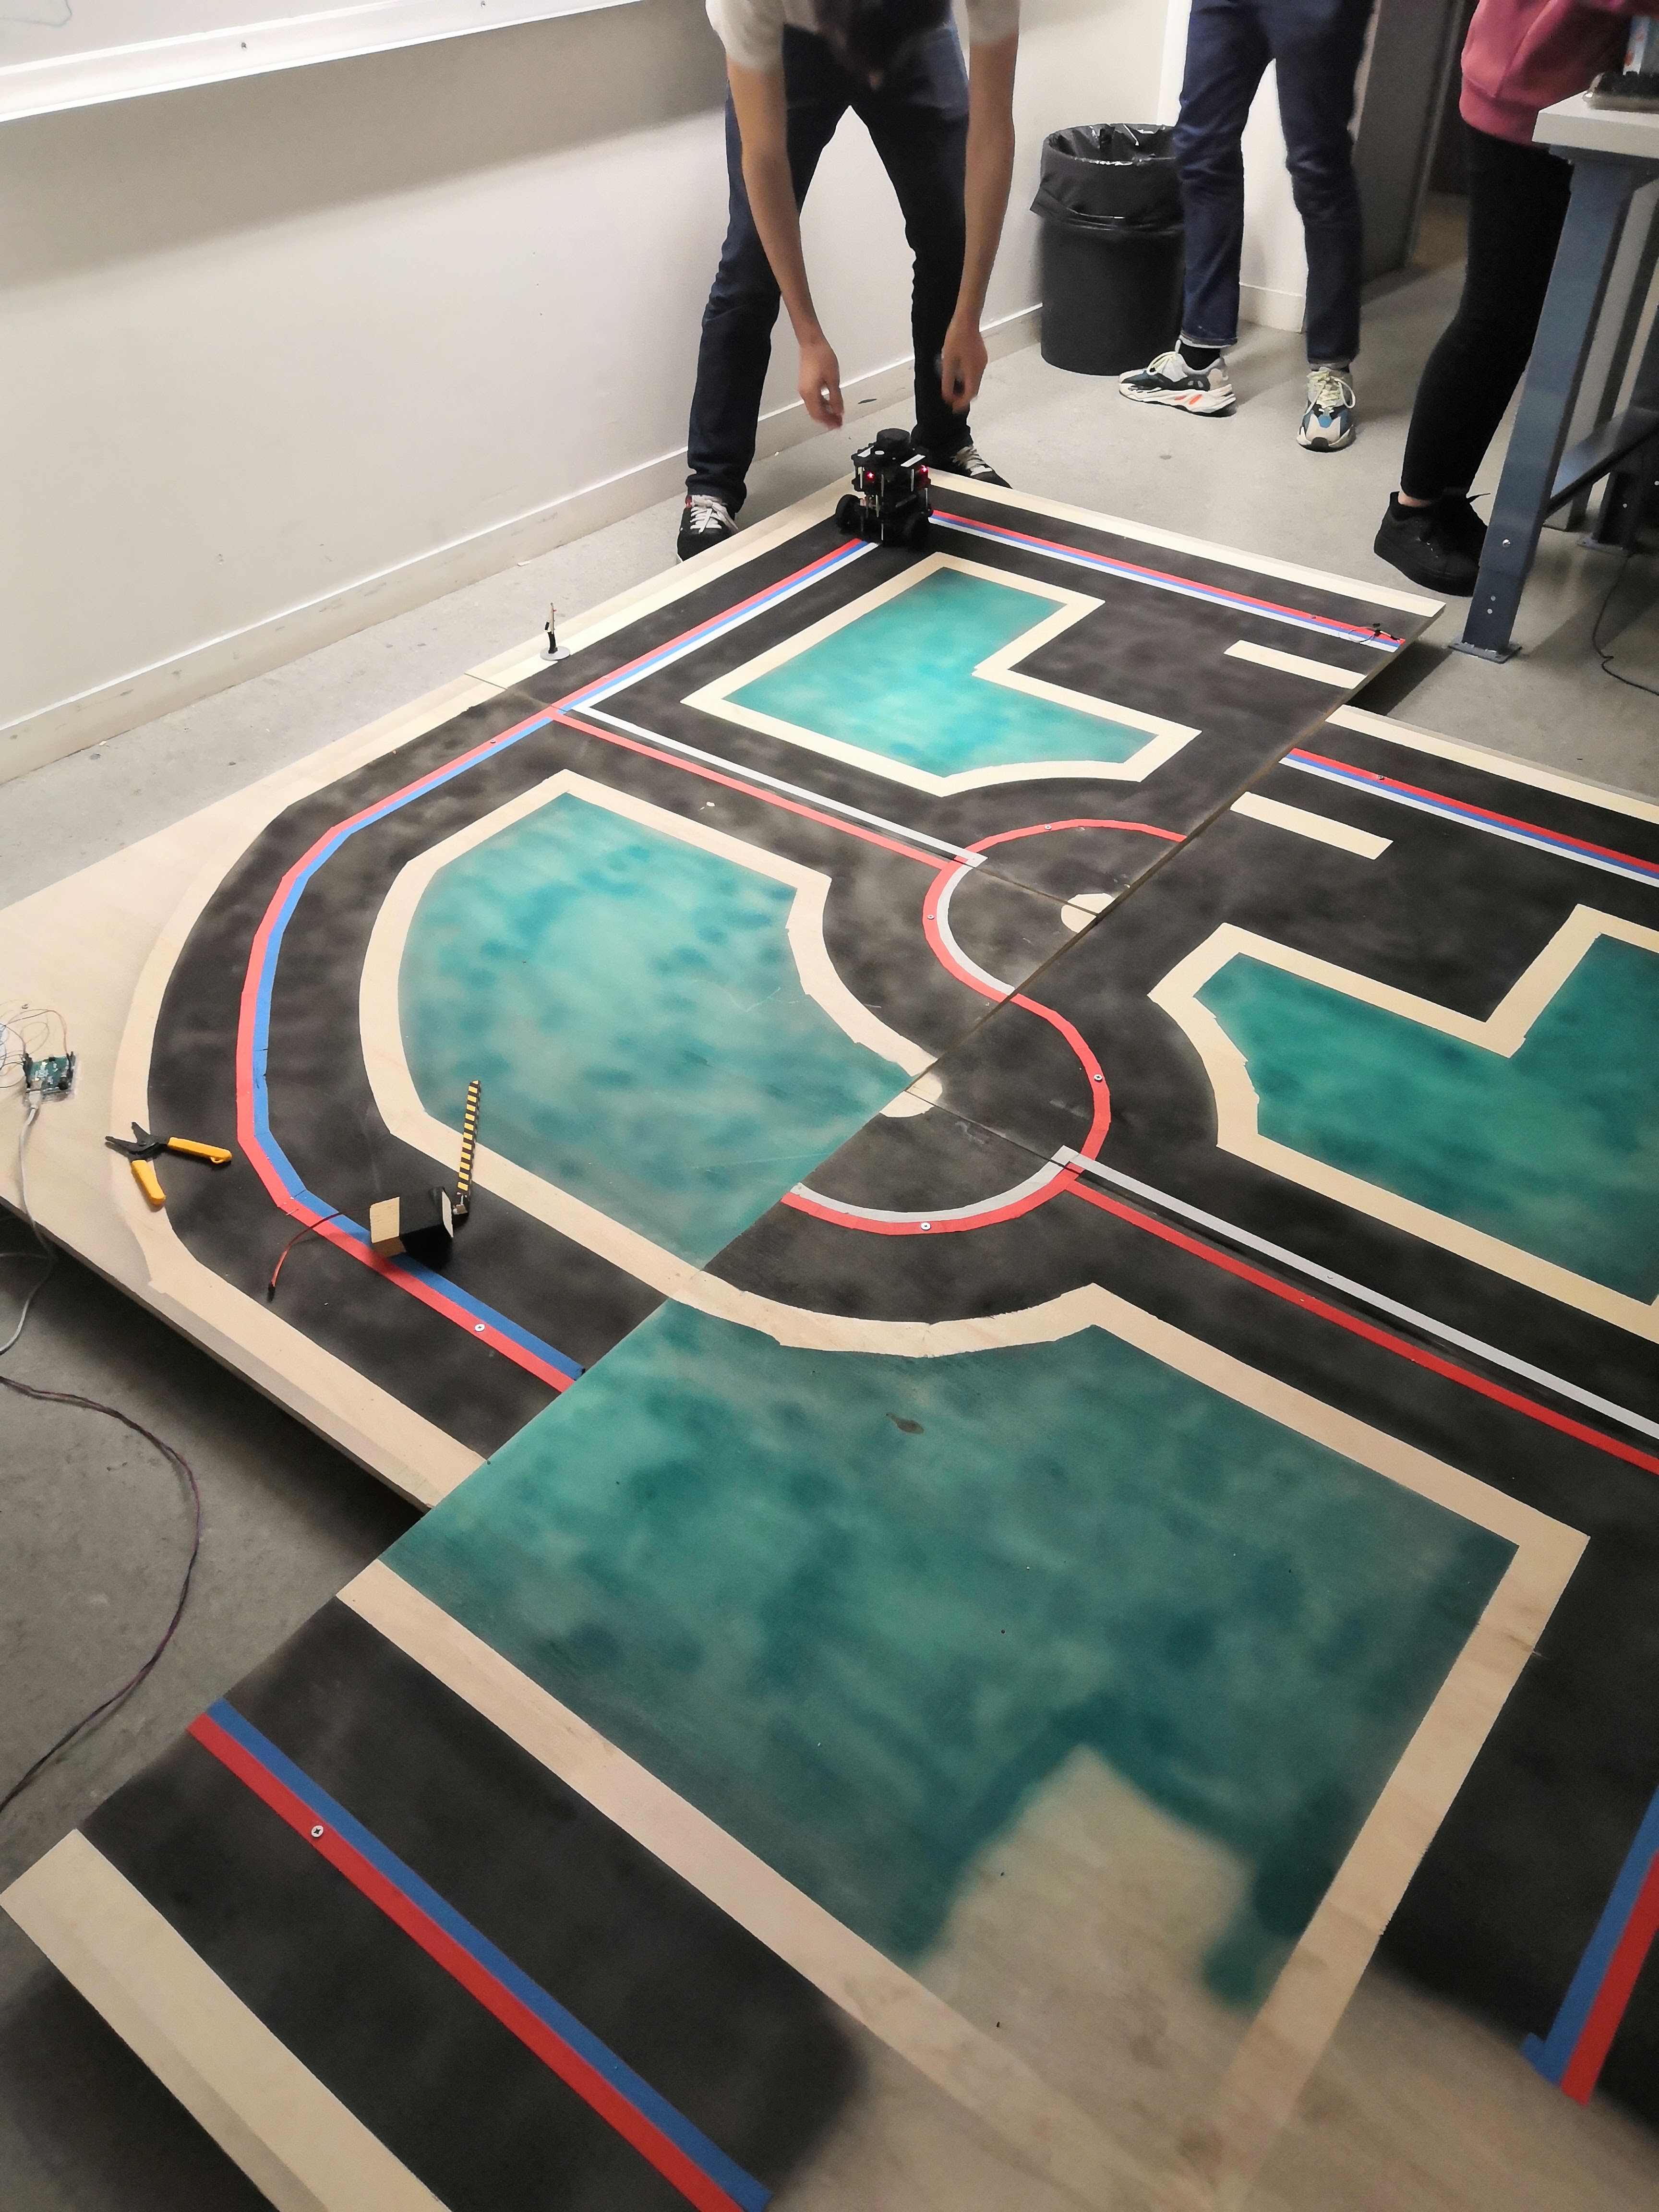
This project is the final project for a group of Master students from the Science for Engineering (Sciences Pour l'Ingénieur) program. The goal was to design and create a virtual and physical arena for the TurtleBot3 Burger robot.
The project was followed closely by the professors Sylvain Argentieri and Fabien Vérité, because the arena was to be used during practical lab session for a robotics class for first year Master students. The team was made of 14 students from different specialties. It was divided into two groups, the first group focused on the robot and the second on the arena. All of the virtual work was done using ROS.
The task of the robot tean was to add a RaspberryPi camera onto the TurtleBot3 Burger. They had to design a support for the camera so it could be fixed to the robot. They had to do this on the virtual robot on ROS and design the support for the real robot using SolidWorks.
The arena was designed to challenge the students that will be using it. Different obstacles (traffic lights, roundabout, crosswalks, level crossing, tunnel) were set up to emulate an urban environment. The robot was able to follow colored lines on the road, different colors represented different difficulty levels. The arena was created on ROS, from scratch, and replicated physically.
Readme credits: mathiasroesler